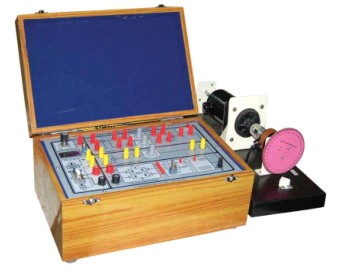
This trainer system is a compact & advanced version for class room experiment set up for the
students to operate and study a practical position control system. A variety of Experiments can
be conducted using this trainer system. The DC motor position control trainer consists of,
1. Controller
2. Converter
3. Mechanical Setup
FEATURES
2 Analog PI controller provided for position
control with cascaded feedback (Position &
Speed)
PI controller provided with Front panel
variable setting for,
a. Variable gain for Proportional controller (P)
b. Variable Integral Time for Integral controller (I)
One Tachogenerator is provided for cascaded feedback.
One F/V converter is provided to convert the pulses to voltage output.
To study the closed loop position control system of DC motor.

.png)